Section 1.8 An Introduction to Linear Transformations

Handout 1.8 An Introduction to Linear Transformations

Definition 1.49 Matrix Transformation.

Let \(A\) be an \(m\times n\) matrix. Define a function
\begin{equation*} T:\mathbb{R}^n \to \mathbb{R}^m, \qquad T(\vec v) = A\vec v . \end{equation*}
A function of this form is called a matrix transformation.
  • The domain of \(T\) is \(\mathbb{R}^n\text{.}\)
  • The codomain (or target) of \(T\) is \(\mathbb{R}^m\text{.}\)
  • The kernel of \(T\) is the set of all vectors \(\vec x\) such that \(T(\vec x) = \vec 0\text{.}\)
  • The vector \(T(\vec x)\) is the image of \(\vec x\) under \(T\text{.}\)
  • The set of all possible images \(T(\vec x)\) is the range of \(T\text{.}\)
This yields another interpretation of the equation \(A\vec x=\vec b\text{:}\)
Many familiar functions have domain and codomain \(\mathbb{R}\text{.}\) For example, the sine function can be described by the rule
\begin{equation*} f\colon \mathbb{R}\to\mathbb{R}, \qquad f(x)=\sin(x). \end{equation*}
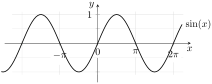
In calculus we often visualize a function via its graph: the horizontal axis represents the domain and the vertical axis the codomain.
Graph of function on the Cartesian plane.
Graph of \(y = \sin(x)\) on the interval \([-2\pi, 2\pi]\) with axes labeled \(x\) and \(y\) and a light grid.
Solution.
  • The domain of \(f\) is \((-\infty, \infty) = \mathbb{R}\text{.}\)
  • The codomain of \(f\) is \((-\infty, \infty) = \mathbb{R}\text{.}\)
  • The range of \(f\) is \([-1,1]\text{.}\)
  • The image of \(x = \frac{\pi}{2}\) is \(y=1\text{.}\)
Graphing is fine when both domain and codomain are \(\mathbb{R}\text{.}\) If the domain is \(\mathbb{R}^2\) and the codomain is \(\mathbb{R}^3\text{,}\) we would need five dimensions to draw the full graph, so a geometric graph is not possible.

Example 1.50.

Let \(A=\begin{bmatrix} 1\amp 1\\[2pt] 0\amp 1\\[2pt] 1\amp 1 \end{bmatrix},\qquad \vec u=\begin{bmatrix} 3\\[2pt] 4 \end{bmatrix},\qquad \vec b=\begin{bmatrix} 7\\[2pt] 5\\[2pt] 7 \end{bmatrix}.\)
Consider the matrix transformation \(T(\vec v)=A\vec v\text{.}\)

(a)

Compute \(T(\vec u)\text{.}\)
Solution.
Note
\begin{equation*} T(\vec u) = A\vec u = \begin{bmatrix} 1 \amp 1 \\ 0 \amp 1 \\ 1 \amp 1 \end{bmatrix}\begin{bmatrix} 3 \\ 4 \end{bmatrix} = 3\begin{bmatrix} 1 \\ 0 \\ 1\end{bmatrix} + 4\begin{bmatrix} 1 \\ 1 \\ 1 \end{bmatrix} = \begin{bmatrix} 7 \\ 4 \\ 7 \end{bmatrix} \end{equation*}
So, \(T(\vec u) = \begin{bmatrix} 7 \\ 4 \\ 7 \end{bmatrix}\text{.}\) Another way of saying this is \(\begin{bmatrix} 7 \\ 4 \\ 7 \end{bmatrix}\) is the image of \(\begin{bmatrix} 3 \\ 4 \end{bmatrix}\) under \(T\text{.}\)

(b)

Find \(\vec v\in\mathbb{R}^2\) so that \(T(\vec v)=\vec b\text{.}\)
Solution.
Note
\begin{equation*} T(\vec v) = \begin{bmatrix} 7 \\ 5 \\ 7 \end{bmatrix} \quad \implies \quad \begin{bmatrix} 1 \amp 1 \\ 0 \amp 1 \\ 1 \amp 1 \end{bmatrix}\vec v = \begin{bmatrix} 7 \\ 5 \\ 7 \end{bmatrix} \end{equation*}
We have that
\begin{equation*} \begin{bmatrix} 1 \amp 1 \amp \rvert \amp 7 \\ 0 \amp 1 \amp \rvert \amp 5 \\ 1 \amp 1 \amp \rvert \amp 7 \end{bmatrix} \sim \begin{bmatrix} 1 \amp 1 \amp \rvert \amp 7 \\ 0 \amp 1 \amp \rvert \amp 5 \\ 0 \amp 0 \amp \rvert \amp 0 \end{bmatrix} \sim \begin{bmatrix} 1 \amp 0 \amp \rvert \amp 2 \\ 0 \amp 1 \amp \rvert \amp 5 \\ 0 \amp 0 \amp \rvert \amp 0 \end{bmatrix} \end{equation*}
Therefore, \(\vec v = \begin{bmatrix} 2 \\ 5 \end{bmatrix}\) is a vector in \(\mathbb{R}^2\) so that \(T(\vec v) = \begin{bmatrix} 7 \\ 5 \\ 7\end{bmatrix}\text{.}\)
We can check this:
\begin{equation*} T(\vec v) = A\vec v = \begin{bmatrix} 1 \amp 1 \\ 0 \amp 1 \\ 1 \amp 1 \end{bmatrix}\begin{bmatrix} 2 \\ 5 \end{bmatrix} = 2\begin{bmatrix} 1 \\ 0 \\ 1\end{bmatrix} + 5\begin{bmatrix} 1 \\ 1 \\ 1 \end{bmatrix} = \begin{bmatrix} 7 \\ 5 \\ 7 \end{bmatrix} \end{equation*}

(c)

Give a vector \(\vec c\in\mathbb{R}^3\) for which there is no \(\vec v\) with \(T(\vec v)=\vec c\text{.}\)
Equivalently: Give a \(\vec c\) not in the range of \(T\text{,}\) i.e., not in the span of the columns of \(A\text{.}\)
Solution.
In order for there to be no \(\vec v\) so that \(T(\vec v) = \vec c\text{,}\) we need for the matrix equation \(A\vec v = \vec c\) to have no solution, or equivalenty, for the underlying linear system to be inconsistent. Let \(\vec c = \begin{bmatrix} c_1 \\ c_2 \\ c_3 \end{bmatrix}\) and note that
\begin{equation*} \begin{bmatrix} A \amp \rvert \amp \vec c\end{bmatrix} = \begin{bmatrix} 1 \amp 1 \amp \rvert \amp c_1 \\ 0 \amp 1 \amp \rvert \amp c_2 \\ 1 \amp 1 \amp \rvert \amp c_3 \end{bmatrix} \sim \begin{bmatrix} 1 \amp 1 \amp \rvert \amp c_1 \\ 0 \amp 1 \amp \rvert \amp c_2 \\ 0 \amp 0 \amp \rvert \amp c_3 - c_1\end{bmatrix} \end{equation*}
Therefore, by TheoremΒ 1.20, the system is inconsistent if and only if \(c_3 - c_1 \neq 0\text{,}\) or equivalently, if and only if \(c_1 \neq c_3\text{.}\) Thus, letting \(\vec c = \begin{bmatrix} 1 \\ 0 \\ 2\end{bmatrix}\) will result in there being no vectors \(\vec v \in \mathbb{R}^2\) with \(T(\vec v) = \vec c\text{.}\)

Definition 1.51 Linear Transformation.

A function \(T:\mathbb{R}^n\to\mathbb{R}^m\) is linear if for all \(\vec u,\vec v\in\mathbb{R}^n\) and all scalars \(c\in\mathbb{R}\text{:}\)
  • \(T(\vec u+\vec v)=T(\vec u)+T(\vec v)\text{,}\)
  • \(T(c\,\vec v)=c\,T(\vec v)\text{.}\)
By linearity, for any scalars \(c_1,\dots,c_k\) and vectors \(\vec v_1,\dots,\vec v_k\text{,}\)
\begin{equation*} T\!\big(c_1\vec v_1+\cdots+c_k\vec v_k\big) \;=\; c_1\,T(\vec v_1)+\cdots+c_k\,T(\vec v_k). \end{equation*}
This is the principle of superposition. In particular, once we know \(T(\vec e_1),\dots,T(\vec e_n)\text{,}\) we can compute \(T(\vec v)\) for any \(\vec v \in \mathbb{R}^n\text{.}\)

Example 1.53.

Suppose \(T(\vec x)=A\vec x\text{.}\) Give a brief geometric description of the action of \(T\) in \(\mathbb{R}^2\) for each matrix.

(a)

\(A=\begin{bmatrix} 0\amp 1\\[2pt] 1\amp 0 \end{bmatrix}\)
Solution.
First, we can see what \(T\) does to specific vectors. Note that
\begin{equation*} T\left(\begin{bmatrix} 1 \\ 0 \end{bmatrix}\right) = \begin{bmatrix} 0 \amp 1 \\ 1 \amp 0 \end{bmatrix}\begin{bmatrix}1 \\ 0 \end{bmatrix} = 1\begin{bmatrix} 0 \\ 1 \end{bmatrix} + 0\begin{bmatrix} 1 \\ 0 \end{bmatrix} = \begin{bmatrix} 0 \\ 1 \end{bmatrix}\text{.} \end{equation*}
Graphing the input vector \(\begin{bmatrix} 1 \\ 0 \end{bmatrix}\) and the output vector \(\begin{bmatrix}0 \\ 1 \end{bmatrix}\) and comparing, we see that the linear transformation \(T\) might have rotated the vector \(90^\circ\) counterclockwise OR it may have reflected the vector about the line \(y = x\) (this swaps the \(x\) and \(y\) entries) OR it may have done something else. Let’s try another vector and see if it narrows down the possibilities. Note that
\begin{equation*} T\left(\begin{bmatrix} 0 \\ 1 \end{bmatrix}\right) = \begin{bmatrix} 0 \amp 1 \\ 1 \amp 0 \end{bmatrix}\begin{bmatrix} 0 \\ 1 \end{bmatrix} = 0\begin{bmatrix} 0 \\ 1 \end{bmatrix} + 1\begin{bmatrix} 1 \\ 0 \end{bmatrix} = \begin{bmatrix} 1 \\ 0 \end{bmatrix}\text{.} \end{equation*}
Again, graphing the input and output vectors and comparing, we see that rotation by \(90^\circ\) counterclockwise is no longer a valid option. It does still seem that reflection about the line \(x = x\) is possible. Let’s now see how the linear transformation changes an arbitrary input. Note that
\begin{equation*} T\left(\begin{bmatrix} x \\ y \end{bmatrix}\right) = \begin{bmatrix} 0 \amp 1 \\ 1 \amp 0 \end{bmatrix}\begin{bmatrix} x \\ y \end{bmatrix} = x\begin{bmatrix} 0 \\ 1 \end{bmatrix} + y\begin{bmatrix} 1 \\ 0 \end{bmatrix} = \begin{bmatrix} y \\ x \end{bmatrix}\text{.} \end{equation*}
Therefore, we see that \(T\left(\begin{bmatrix} x \\ y \end{bmatrix}\right) = \begin{bmatrix} y \\ x \end{bmatrix}\) for any input vector \(\vec x = \begin{bmatrix} x \\ y \end{bmatrix}\text{.}\) Thus, the linear transformation \(T\) reflects vectors about the line \(y = x\text{.}\)

(b)

\(A=\begin{bmatrix} 1\amp 0\\[2pt] 0\amp 0 \end{bmatrix}\)
Solution.
Again, we can start to get an idea of how this transformation affects vectors geometrically by seeing how it acts on particular vectors. Note that
\begin{equation*} T\left(\begin{bmatrix} 1 \\ 0 \end{bmatrix}\right) = \begin{bmatrix} 1 \amp 0 \\ 0 \amp 0 \end{bmatrix}\begin{bmatrix}1 \\ 0 \end{bmatrix} = 1\begin{bmatrix} 1 \\ 0 \end{bmatrix} + 0\begin{bmatrix} 0 \\ 0 \end{bmatrix} = \begin{bmatrix} 1 \\ 0 \end{bmatrix}\text{.} \end{equation*}
So, \(T\left(\begin{bmatrix} 1 \\ 0 \end{bmatrix}\right) = \begin{bmatrix} 1 \\ 0 \end{bmatrix}\) which makes it look like \(T\) doesn’t do anything. Let’s try another input vector:
\begin{equation*} T\left(\begin{bmatrix} 0 \\ 1 \end{bmatrix}\right) = \begin{bmatrix} 1 \amp 0 \\ 0 \amp 0 \end{bmatrix}\begin{bmatrix} 0 \\ 1 \end{bmatrix} = 0\begin{bmatrix} 1 \\ 0 \end{bmatrix} + 1\begin{bmatrix} 0 \\ 0 \end{bmatrix} = \begin{bmatrix} 0 \\ 0 \end{bmatrix}\text{.} \end{equation*}
This time, \(T\) sent our input vector to the origin. Maybe you can see what kind of geometric operation can act on the previous two vectors in such a way. If not, let’s see what \(T\) does to an arbitrary vector. Note that
\begin{equation*} T\left(\begin{bmatrix} x \\ y \end{bmatrix}\right) = \begin{bmatrix} 1 \amp 0 \\ 0 \amp 0 \end{bmatrix}\begin{bmatrix} x \\ y \end{bmatrix} = x\begin{bmatrix} 1 \\ 0 \end{bmatrix} + y\begin{bmatrix} 0 \\ 0 \end{bmatrix} = \begin{bmatrix} x \\ 0 \end{bmatrix}\text{.} \end{equation*}
Now, we see that \(T\) is projecting vectors onto the \(x\)-axis. (If you don’t know what projection is, we will discuss it Chapter 6.)

(c)

\(A=\begin{bmatrix} k\amp 0\\[2pt] 0\amp k \end{bmatrix}\) for \(k\in\mathbb{R}\)
Solution.
Let’s go ahead and see what \(T\) does to an arbitrary vector:
\begin{equation*} T\left(\begin{bmatrix} x \\ y \end{bmatrix}\right) = \begin{bmatrix} k \amp 0 \\ 0 \amp k \end{bmatrix}\begin{bmatrix} x \\ y \end{bmatrix} = x\begin{bmatrix} k \\ 0 \end{bmatrix} + y\begin{bmatrix} 0 \\ k \end{bmatrix} = \begin{bmatrix} xk \\ yk \end{bmatrix} = k\begin{bmatrix} x \\ y \end{bmatrix}\text{.} \end{equation*}
Therefore, \(T\) simply multiplies the input vector by \(k\text{.}\) Geometrically, this results in the input vector being scaled by \(|k|\) and rotated by \(180^\circ\) if \(k < 0\text{.}\)

Example 1.54.

Describe the effect of \(T_A\) on vectors in \(\mathbb{R}^3\text{.}\)

(a)

\(A=\begin{bmatrix} 1\amp 0\amp 0\\[2pt] 0\amp 1\amp 0\\[2pt] 0\amp 0\amp 0 \end{bmatrix}\)
Solution.
Feel free to start by seeing what \(T\) does to particular inputs. We will go ahead and see how \(T\) acts on an arbitrary vector. Note that
\begin{equation*} T\left(\begin{bmatrix} x \\ y \\ z \end{bmatrix}\right) = \begin{bmatrix} 1 \amp 0 \amp 0 \\ 0 \amp 1\amp 0 \\ 0 \amp 0 \amp 0 \end{bmatrix}\begin{bmatrix} x \\ y \\ z \end{bmatrix} = x\begin{bmatrix} 1 \\ 0 \\ 0 \end{bmatrix} + y\begin{bmatrix} 0 \\ 1 \\ 0 \end{bmatrix} + z\begin{bmatrix} 0 \\ 0 \\ 0 \end{bmatrix} = \begin{bmatrix} x \\ y \\ 0 \end{bmatrix}\text{.} \end{equation*}
Note that \(T\) sets the \(z\)-compenent of any input vector to \(0\text{.}\) Geometrically, this result in the input vector getting projected onto the \(xy\)-plane.

(b)

\(A=\begin{bmatrix} 1\amp 0\amp 0\\[2pt] 0\amp -1\amp 0\\[2pt] 0\amp 0\amp 1 \end{bmatrix}\)
Solution.
Note that
\begin{equation*} T\left(\begin{bmatrix} x \\ y \\ z \end{bmatrix}\right) = \begin{bmatrix} 1 \amp 0 \amp 0 \\ 0 \amp -1 \amp 0 \\ 0 \amp 0 \amp 1 \end{bmatrix}\begin{bmatrix} x \\ y \\ z \end{bmatrix} = x\begin{bmatrix} 1 \\ 0 \\ 0 \end{bmatrix} + y\begin{bmatrix} 0 \\ -1 \\ 0 \end{bmatrix} + z\begin{bmatrix} 0 \\ 0 \\ 1 \end{bmatrix} = \begin{bmatrix} x \\ -y \\ z \end{bmatrix}\text{.} \end{equation*}
Note that \(T\) negates the \(y\)-compenent of any input vector. Geometrically, this result in the input vector getting reflected about the \(xz\)-plane.

Example 1.55.

A linear transformation \(T:\mathbb{R}^2\to\mathbb{R}^3\) satisfies
\begin{equation*} T\!\left(\begin{bmatrix}1\\[2pt]0\end{bmatrix}\right) = \begin{bmatrix}5\\[2pt]-7\\[2pt]2\end{bmatrix}, \qquad T\!\left(\begin{bmatrix}0\\[2pt]1\end{bmatrix}\right) = \begin{bmatrix}-3\\[2pt]8\\[2pt]0\end{bmatrix}. \end{equation*}
What is the matrix that represents \(T\text{?}\)
Solution.
We want to find \(A\) so that \(T(\vec x) = A\vec x \text{.}\) Let’s use the given data points and the fact the \(T\) is a linear transformation to determine how \(T\) acts on an arbitrary vector. First, note that we can represent an arbitrary vector \(\begin{bmatrix} x \\ y \end{bmatrix}\) as a linear combination of \(\begin{bmatrix} 1 \\ 0 \end{bmatrix}\) and \(\begin{bmatrix} 0 \\ 1 \end{bmatrix}\) in the following way.
\begin{equation*} \begin{bmatrix} x \\ y \end{bmatrix} = x\begin{bmatrix} 1 \\ 0 \end{bmatrix} + y\begin{bmatrix} 0 \\ 1 \end{bmatrix}\text{.} \end{equation*}
Applying the linear transformation \(T\) to both sides yields
\begin{equation*} T\left(\begin{bmatrix} x \\ y \end{bmatrix}\right) = T\left(x\begin{bmatrix} 1 \\ 0 \end{bmatrix} + y\begin{bmatrix} 0 \\ 1 \end{bmatrix}\right)\text{.} \end{equation*}
Since \(T\) is a linear transfomration, we know that \(T(\vec u + \vec v) = T(\vec u) + T(\vec v)\text{.}\) Therefore, we have that
\begin{equation*} T\left(\begin{bmatrix} x \\ y \end{bmatrix}\right) = T\left(x\begin{bmatrix}1 \\ 0 \end{bmatrix}\right) + T\left(y\begin{bmatrix} 0 \\ 1 \end{bmatrix}\right) \end{equation*}
Another property of linear transformations we can use is that \(T(c\vec v) = cT(\vec v)\text{.}\) Thus, we have that
\begin{equation*} T\left(\begin{bmatrix} x \\ y \end{bmatrix}\right) = x \ T\left(\begin{bmatrix} 1 \\ 0 \end{bmatrix}\right) + y \ T\left(\begin{bmatrix} 0 \\ 1 \end{bmatrix}\right)\text{.} \end{equation*}
Subbing in the given information, we have that
\begin{equation*} T\left(\begin{bmatrix} x \\ y \end{bmatrix}\right) = x\begin{bmatrix} 5 \\ -7 \\ 2 \end{bmatrix} + y\begin{bmatrix} -3 \\ 8 \\ 0 \end{bmatrix} = \begin{bmatrix} 5 \amp -3 \\ -7 \amp 8 \\ 2 \amp 0 \end{bmatrix}\begin{bmatrix} x \\ y \end{bmatrix}\text{.} \end{equation*}
Therefore, we have that \(A = \begin{bmatrix} 5 \amp -3 \\ -7 \amp 8 \\ 2 \amp 0 \end{bmatrix}\) is the matrix that represents \(T\text{.}\)
Note: The matrix representing a linear transformation is usually not formed by simply putting the given vectors as the columns. It was in this example since we were told what \(T\) did to the standard vectors. We will learn more about standard vectors and the matrix of a linear transformation in the next section.